Robotics
Where hardware, software and machine intelligence come together.
Our research is interdisciplinary and focuses on sensing, planning, reasoning, and control of single and multi-agent systems, including both manipulation and mobile robots. We strive to develop algorithms and methods for factory automation, smart building and transportation applications using machine learning, computer vision, RF/optical sensing, wireless communications, control theory and signal processing. Key research themes include bin picking and object manipulation, sensing and mapping of indoor areas, coordinated control of robot swarms, as well as robot learning and simulation.
Quick Links
-
Researchers
Stefano
Di Cairano
Daniel N.
Nikovski
Siddarth
Jain
Arvind
Raghunathan
Radu
Corcodel
Yebin
Wang
William S.
Yerazunis
Abraham P.
Vinod
Chiori
Hori
Toshiaki
Koike-Akino
Alexander
Schperberg
Avishai
Weiss
Anoop
Cherian
Jonathan
Le Roux
Tim K.
Marks
Scott A.
Bortoff
Ye
Wang
Bingnan
Wang
Matthew
Brand
Purnanand
Elango
Yoshiki
Masuyama
Pedro
Miraldo
Philip V.
Orlik
Abraham
Goldsmith
Jianlin
Guo
Jordan
Leung
Jing
Liu
Hassan
Mansour
Saviz
Mowlavi
Zhaolin
Ren
Kento
Tomita
Anthony
Vetro
Pu
(Perry)
Wang
Kei
Suzuki
-
Awards
-
AWARD MERL Team Wins IROS 2026 Humanoid IKEA Assembly Challenge Date: October 1, 2026
Awarded to: Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, Ye Wang, Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu
MERL Contacts: Toshiaki Koike-Akino; Jing Liu; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
The challenge asked teams to develop autonomous robot policies for a Unitree G1 humanoid robot to assemble an IKEA UTTER table from its component parts. The robot had to perform the task autonomously at the competition venue, requiring capabilities including perception, bimanual manipulation, spatial reasoning, planning, and control. Human intervention was penalized, and teams were evaluated based on assembly progress and completion time.
MERL competed as MEL-Craft and achieved first place in the competition. The result demonstrates progress toward reliable humanoid robots capable of performing complex, contact-rich manipulation tasks in real-world environments, an important direction for physical AI and general-purpose robotic systems.
The MERL team members were Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Harsh Singh, Chak Lam Shek, Maxwell Asselmeier, and Haodi Hu.
The Humanoid IKEA Assembly Challenge was held as part of IROS 2026, the IEEE/RSJ International Conference on Intelligent Robots and Systems.
- MERL's team MEL-Craft won first place in the Humanoid IKEA Assembly Challenge at IROS 2026, held in Pittsburgh, Pennsylvania. The inaugural competition attracted approximately 34 registered teams worldwide.
-
AWARD Honorable Mention Award at NeurIPS 23 Instruction Workshop Date: December 15, 2023
Awarded to: Lingfeng Sun, Devesh K. Jha, Chiori Hori, Siddharth Jain, Radu Corcodel, Xinghao Zhu, Masayoshi Tomizuka and Diego Romeres
MERL Contacts: Radu Corcodel; Chiori Hori; Siddarth Jain
Research Areas: Artificial Intelligence, Machine Learning, RoboticsBrief- MERL Researchers received an "Honorable Mention award" at the Workshop on Instruction Tuning and Instruction Following at the NeurIPS 2023 conference in New Orleans. The workshop was on the topic of instruction tuning and Instruction following for Large Language Models (LLMs). MERL researchers presented their work on interactive planning using LLMs for partially observable robotic tasks during the oral presentation session at the workshop.
-
AWARD MERL Researchers Win Best Workshop Poster Award at the 2023 IEEE International Conference on Robotics and Automation (ICRA) Date: June 2, 2023
Awarded to: Yuki Shirai, Devesh Jha, Arvind Raghunathan and Dennis Hong
MERL Contact: Arvind Raghunathan
Research Areas: Artificial Intelligence, Optimization, RoboticsBrief- MERL's paper titled: "Closed-Loop Tactile Controller for Tool Manipulation" Won the Best Poster Award in the workshop on "Embracing contacts : Making robots physically interact with our world". First author and MERL intern, Yuki Shirai, was presented with the award at a ceremony held at ICRA in London. MERL researchers Devesh Jha, Principal Research Scientist, and Arvind Raghunathan, Senior Principal Research Scientist and Senior Team Leader as well as Prof. Dennis Hong of University of California, Los Angeles are also coauthors.
The paper presents a technique to manipulate an object using a tool in a closed-loop fashion using vision-based tactile sensors. More information about the workshop and the various speakers can be found here https://sites.google.com/view/icra2023embracingcontacts/home.
- MERL's paper titled: "Closed-Loop Tactile Controller for Tool Manipulation" Won the Best Poster Award in the workshop on "Embracing contacts : Making robots physically interact with our world". First author and MERL intern, Yuki Shirai, was presented with the award at a ceremony held at ICRA in London. MERL researchers Devesh Jha, Principal Research Scientist, and Arvind Raghunathan, Senior Principal Research Scientist and Senior Team Leader as well as Prof. Dennis Hong of University of California, Los Angeles are also coauthors.
See All Awards for MERL -
-
News & Events
-
NEWS MERL contributes to IROS 2026 Date: September 27, 2026 - October 1, 2026
Where: The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
MERL Contacts: Siddarth Jain; Toshiaki Koike-Akino; Jing Liu; Daniel N. Nikovski; Arvind Raghunathan; Alexander Schperberg; Kei Suzuki; Ye Wang
Research Areas: Artificial Intelligence, Computer Vision, Control, Machine Learning, Optimization, Robotics, Signal ProcessingBrief- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
Main Conference Paper
- ORIGAMI: Object Representation Inferred Geometrically for Articulated ManIpulation, Yunfu Deng and Daniel N. Nikovski (TR2026-141)
The work introduces a geometric representation for articulated-object manipulation, enabling robots to infer compact representations of previously unknown articulated mechanisms for downstream learning and control.
Workshop Papers
- Deliberate Practice: Learning Robot Skills under a Budget Shivam Vats, Sudarshan Harithas, Mete Akbulut, Arvind Raghunathan, and George Konidaris (TR2026-147)
- ReCoVLA: VLM-Guided Reward Compilation for Failure Recovery in Vision-Language-Action Policies, Haodi Hu, Chung-Ta Huang, Jing Liu, Ye Wang, Kei Suzuki, Matthew Brand, and Toshiaki Koike-Akino (TR2026-148)
- Test-Time Attention: Can Robots Better Follow Commands? Jing Liu, Ye Wang, Kei Suzuki, and Toshiaki Koike-Akino (TR2026-142)
- Read the Manual: Grounding Behavior Tree Synthesis for Multi-Machine Factory Operation, Chak Lam Shek, Ye Wang, Jing Liu, Kei Suzuki, Pratap Tokekar, and Toshiaki Koike-Akino (TR2026-149)
- DYNAMIT: Dynamic Zero-Shot Manipulation via Instruction-Grounded Visual Tracking and Interception in Industrial Conveyor Environments, Harsh Singh, Kei Suzuki, Ye Wang, Jing Liu, Paola Cascante-Bonilla, and Toshiaki Koike-Akino (TR2026-146)
Together, these works address a range of challenges in modern robotics, including articulated-object manipulation, efficient robot skill learning, vision-language-action policies, test-time adaptation, autonomous factory operation, and dynamic manipulation. The paper on ReCoVLA was nominated as a spotlight talk.
Robotics Community Contributions
MERL Principal Research Scientist Dr. Siddarth Jain participated in the IEEE Robotics and Automation Letters (RA-L) editorial board meeting at IROS. Dr. Jain serves as an Associate Editor of RA-L, contributing to the peer-review and editorial activities of the robotics research community.
Former MERL scientist Dr. Diego Romeres was also among the organizers of the 1st International Workshop on Industrial Applications of Robot Learning (IARL 2026). The workshop brought together researchers from academia and industry to discuss how advances in robot learning can be translated into reliable and scalable real-world industrial robotic systems.
Humanoid IKEA Assembly Challenge
MERL also participated in the IROS 2026 Humanoid IKEA Assembly Challenge with Team MEL-Craft. The team achieved first place in the competition, demonstrating autonomous humanoid manipulation capabilities for a challenging furniture-assembly task. The MEL-Craft team included MERL researchers Kei Suzuki, Jing Liu, Alexander Schperberg, Toshiaki Koike-Akino, and Ye Wang, with contributions from MERL interns Haodi Hu, Harsh Singh, Chak Lam Shek, and Maxwell Asselmeier. The competition achievement is highlighted separately in MERL's related award announcement.
About IROS
The IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) is a major international robotics conference bringing together researchers, engineers, and industry practitioners working across intelligent robots and systems. IROS 2026 took place in Pittsburgh from September 27 to October 1, 2026.
- MERL made broad contributions to the technical program and robotics community at the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026), held in Pittsburgh, Pennsylvania. MERL researchers presented one main-conference paper and five workshop papers, participated in an editorial board meeting, competed in the Humanoid IKEA Assembly Challenge, and contributed to the organization of an IROS workshop.
-
NEWS MERL researchers present 9 papers at IEEE ICRA 2026 Date: June 1, 2026 - June 5, 2026
Where: Vienna, Austria
MERL Contacts: Radu Corcodel; Stefano Di Cairano; Purnanand Elango; Siddarth Jain; Alexander Schperberg; Kento Tomita
Research Areas: Artificial Intelligence, Computer Vision, Control, Dynamical Systems, Machine Learning, Optimization, RoboticsBrief- MERL researchers presented nine papers at the recently concluded IEEE International Conference on Robotics and Automation (ICRA) 2026 in Vienna, Austria. The papers covered a broad set of topics in robotics, including robot perception, visuo-tactile sensing, contact and pose estimation, manipulation, reinforcement learning, diffusion policies, loco-manipulation, contact-implicit trajectory optimization, legged locomotion, localization, and perception-aware planning.
IEEE ICRA is the flagship conference of the IEEE Robotics and Automation Society and the world’s largest and most comprehensive technical conference focused on research advances and the latest technological developments in robotics. The event attracts nearly 8,000 participants and receives more than 5,000 paper submissions.
- MERL researchers presented nine papers at the recently concluded IEEE International Conference on Robotics and Automation (ICRA) 2026 in Vienna, Austria. The papers covered a broad set of topics in robotics, including robot perception, visuo-tactile sensing, contact and pose estimation, manipulation, reinforcement learning, diffusion policies, loco-manipulation, contact-implicit trajectory optimization, legged locomotion, localization, and perception-aware planning.
See All News & Events for Robotics -
-
Research Highlights
-
Internships
-
OR0329: Internship - Robotic Disassembly
-
OR0313: Internship - Foundation Models for Humanoid Robots
-
CI0314: Internship - Embodied AI & Humanoid Robotics
See All Internships for Robotics -
-
Openings
-
CI0177: Postdoctoral Research Fellow - Agentic AI
-
OR0293: Research Scientist - Robotics
-
OR0294: Research Scientist - Robotics Team Leader
See All Openings at MERL -
-
Recent Publications
- , "Deliberate Practice: Learning Robot Skills under a Budget", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, October 2026.BibTeX TR2026-147 PDF
- @inproceedings{Vats2026oct,
- author = {Vats, Shivam and Harithas, Sudarshan and Akbulut, Mete and Raghunathan, Arvind and Konidaris, George},
- title = {{Deliberate Practice: Learning Robot Skills under a Budget}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop},
- year = 2026,
- month = oct,
- url = {https://www.merl.com/publications/TR2026-147}
- }
- , "Spatio-temporal monitoring using energy-constrained, sensing robots", IEEE Transactions on Automation Science and Engineering, September 2026.BibTeX TR2026-144 PDF Video
- @article{Buyukkocak2026sep,
- author = {Buyukkocak, Ali and {Di Cairano}, Stefano and Vinod, Abraham P.},
- title = {{Spatio-temporal monitoring using energy-constrained, sensing robots}},
- journal = {IEEE Transactions on Automation Science and Engineering},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-144}
- }
- , "ORIGAMI: Object Representation Inferred Geometrically for Articulated ManIpulation", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), September 2026.BibTeX TR2026-141 PDF
- @inproceedings{Deng2026sep,
- author = {Deng, Yunfu and Nikovski, Daniel N.},
- title = {{ORIGAMI: Object Representation Inferred Geometrically for Articulated ManIpulation}},
- booktitle = {IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-141}
- }
- , "Plan and Double-Check: Streaming Multimodal Q-Former for Online Robot Action Generation", Interspeech, September 2026.BibTeX TR2026-136 PDF
- @inproceedings{Hori2026sep,
- author = {{Hori, Chiori and Korekata, Ryosuke and Kambara, Motonari and Masuyama, Yoshiki and Jain, Siddarth and Corcodel, Radu and Romeres, Diego and Le Roux, Jonathan}},
- title = {{Plan and Double-Check: Streaming Multimodal Q-Former for Online Robot Action Generation}},
- booktitle = {Interspeech},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-136}
- }
- , "Radar Sensing in Industrial and Mobile Robotics: A Review", IEEE Sensors Journal, September 2026.BibTeX TR2026-145 PDF
- @inproceedings{Pandharipande2026sep,
- author = {Pandharipande, Ashish and Wang, Pu and Hakobyan, Gor},
- title = {{Radar Sensing in Industrial and Mobile Robotics: A Review}},
- booktitle = {IEEE Sensors Journal},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-145}
- }
- , "Constrained Sampling MPC for Safe Contact-Rich Control: From Exploration to Precision via Hybrid Refinement⋆", IFAC World Congress, September 2026.BibTeX TR2026-119 PDF
- @inproceedings{Wang2026sep,
- author = {Wang, Chenghao and Romeres, Diego and Schperberg, Alexander and Li, Na and Wang, Yebin},
- title = {{Constrained Sampling MPC for Safe Contact-Rich Control: From Exploration to Precision via Hybrid Refinement⋆}},
- booktitle = {IFAC World Congress},
- year = 2026,
- month = sep,
- url = {https://www.merl.com/publications/TR2026-119}
- }
- , "Fast Adaptive Planning for Autonomous Tractor-Trailer Systems via Iterative LQR Steering", IEEE Conference on Automation and Science Engineering, August 2026.BibTeX TR2026-118 PDF
- @inproceedings{Zhou2026aug,
- author = {Zhou, Tianyu and Wang, Yebin and Umat, Akhil and Tiwari, Astha and {Di Cairano}, Stefano},
- title = {{Fast Adaptive Planning for Autonomous Tractor-Trailer Systems via Iterative LQR Steering}},
- booktitle = {IEEE Conference on Automation and Science Engineering},
- year = 2026,
- month = aug,
- url = {https://www.merl.com/publications/TR2026-118}
- }
- , "Learning State Representations of Articulated Robot Arms from Visual Observations", International Conference on Control, Decision, and Information Technologies (CoDIT), July 2026.BibTeX TR2026-107 PDF
- @inproceedings{Deng2026jul,
- author = {{Deng, Yunfu and Nikovski, Daniel N.}},
- title = {{Learning State Representations of Articulated Robot Arms from Visual Observations}},
- booktitle = {International Conference on Control, Decision, and Information Technologies (CoDIT)},
- year = 2026,
- month = jul,
- url = {https://www.merl.com/publications/TR2026-107}
- }
- , "Deliberate Practice: Learning Robot Skills under a Budget", IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Workshop, October 2026.
-
Videos
-
Software & Data Downloads
-
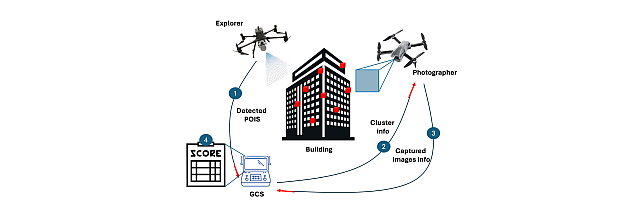
ROS 2 Cooperative Aerial Robots Inspection Challenge -
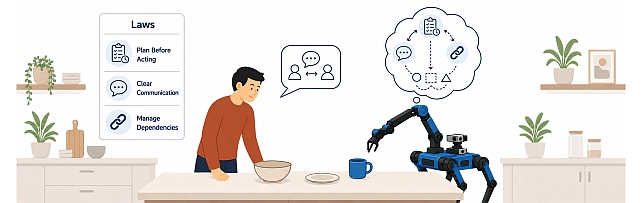
Learning Laws of Cooperation for Modeling Embodied Multi-Agent Behavior -
Learning Unified Multimodal Extrinsic Contact Estimation -
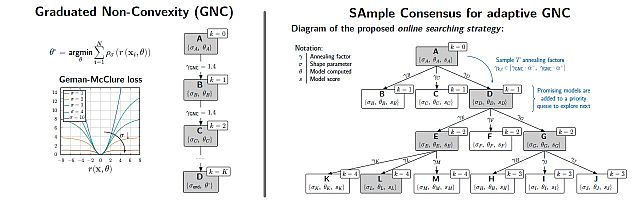
SAmple Consensus for Adaptive Graduated Non-Convexity -
Lagrangian Inspired Polynomial for Robot Inverse Dynamics -
Monte Carlo Probabilistic Inference for Learning COntrol -
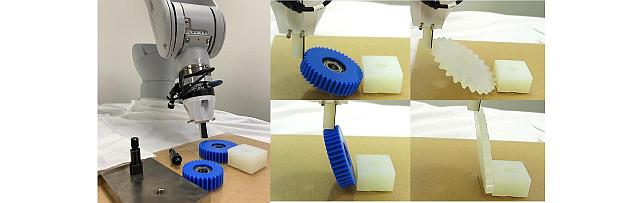
Python-based Robotic Control & Optimization Package -
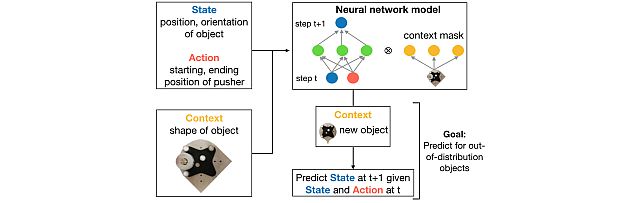
Context-Aware Zero Shot Learning -
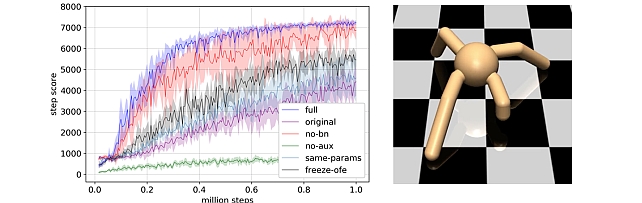
Online Feature Extractor Network -
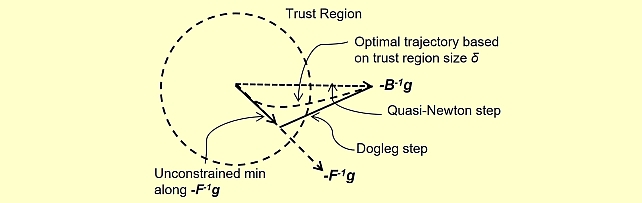
Quasi-Newton Trust Region Policy Optimization -
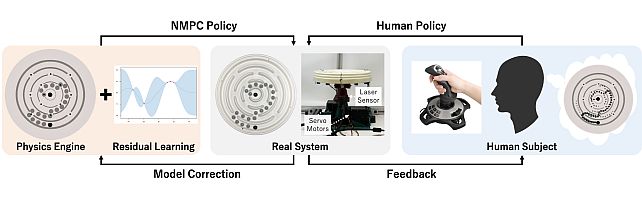
Circular Maze Environment
-